Available — Full-Time Roles, May 2026

Sidharth
Jain

Robotics & Embedded Systems Engineer

I build robotics systems that deploy in the real world — from PCB design to clinical validation. Not just prototypes. Seven iterations. 100+ patient deployments. Patented. Funded. Validated by clinicians.

100+ Patients
$120K Funded
2 Patents
200+ Students
Scroll
// Technical Skills

What I Build With

01

Embedded & Hardware

  • ESP32-S3 / TI Microcontrollers
  • Custom PCB Design
  • FreeRTOS Task Scheduling
  • I2C / SPI / UART
  • TCP/UDP Real-Time Streaming
  • IMU Calibration & FSR Modeling
  • Power Management
  • On-Device Filtering

02

Robotics & Control

  • LQR / PD / PID / MPC
  • Forward & Inverse Kinematics
  • Trajectory Planning (Bézier)
  • Sensor Fusion (EKF, Quaternion)
  • MuJoCo Simulation
  • Motion Planning
  • Biomechanics & Gait Analysis
  • Hardware-Software Integration

03

Machine Learning & AI

  • PyTorch / TensorFlow
  • scikit-learn / Ensemble Models
  • Time-Series Feature Engineering
  • ONNX / TensorRT / CUDA
  • RAG (FAISS, Pinecone)
  • Multi-Agent Automation
  • Computer Vision (CNN)
  • End-to-End ML Pipelines

04

Software & Infra

  • Python (Advanced) / C++ / TS
  • FastAPI / Docker
  • SQL / PostgreSQL
  • GCP / AWS
  • WebSockets / REST APIs
  • Next.js / React
  • FAISS / Pinecone Vector DBs
  • PDF Report Generation
Languages Python C++ TypeScript JavaScript Java R SQL

// Selected Work

Systems That Deploy

001

Embedded Systems // Sensor Fusion // Medical Devices

GATTII — Wearable Gait Analysis System

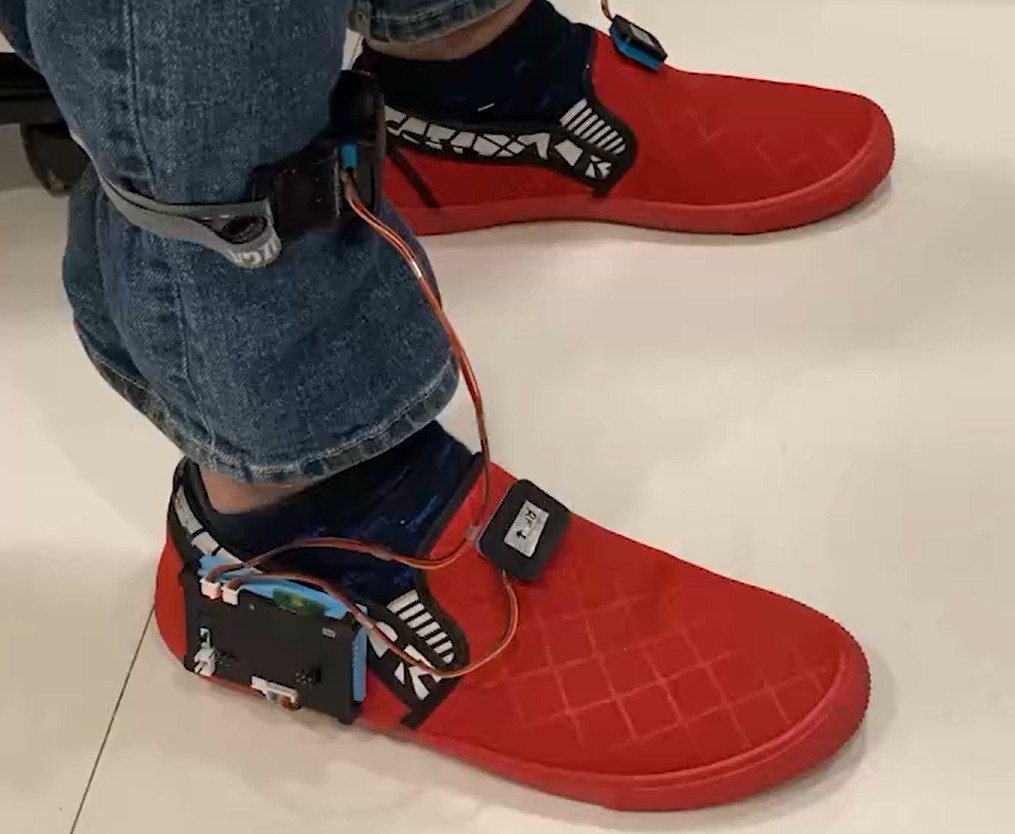
Brings clinical-grade gait analysis from $100k+ motion-capture labs to community physiotherapy clinics in Mumbai. Custom PCB → FreeRTOS firmware → EKF sensor fusion → FastAPI clinical backend. Seven iterations to solve drift, latency, and pressure map reconstruction.

Patented #377581 $120K Funded Medical Device Deployed
24 Gait Params
35% Latency ↓
100+ Patients
R²=.91 CoP Corr.
Read Case Study →
GATTII worn on feet
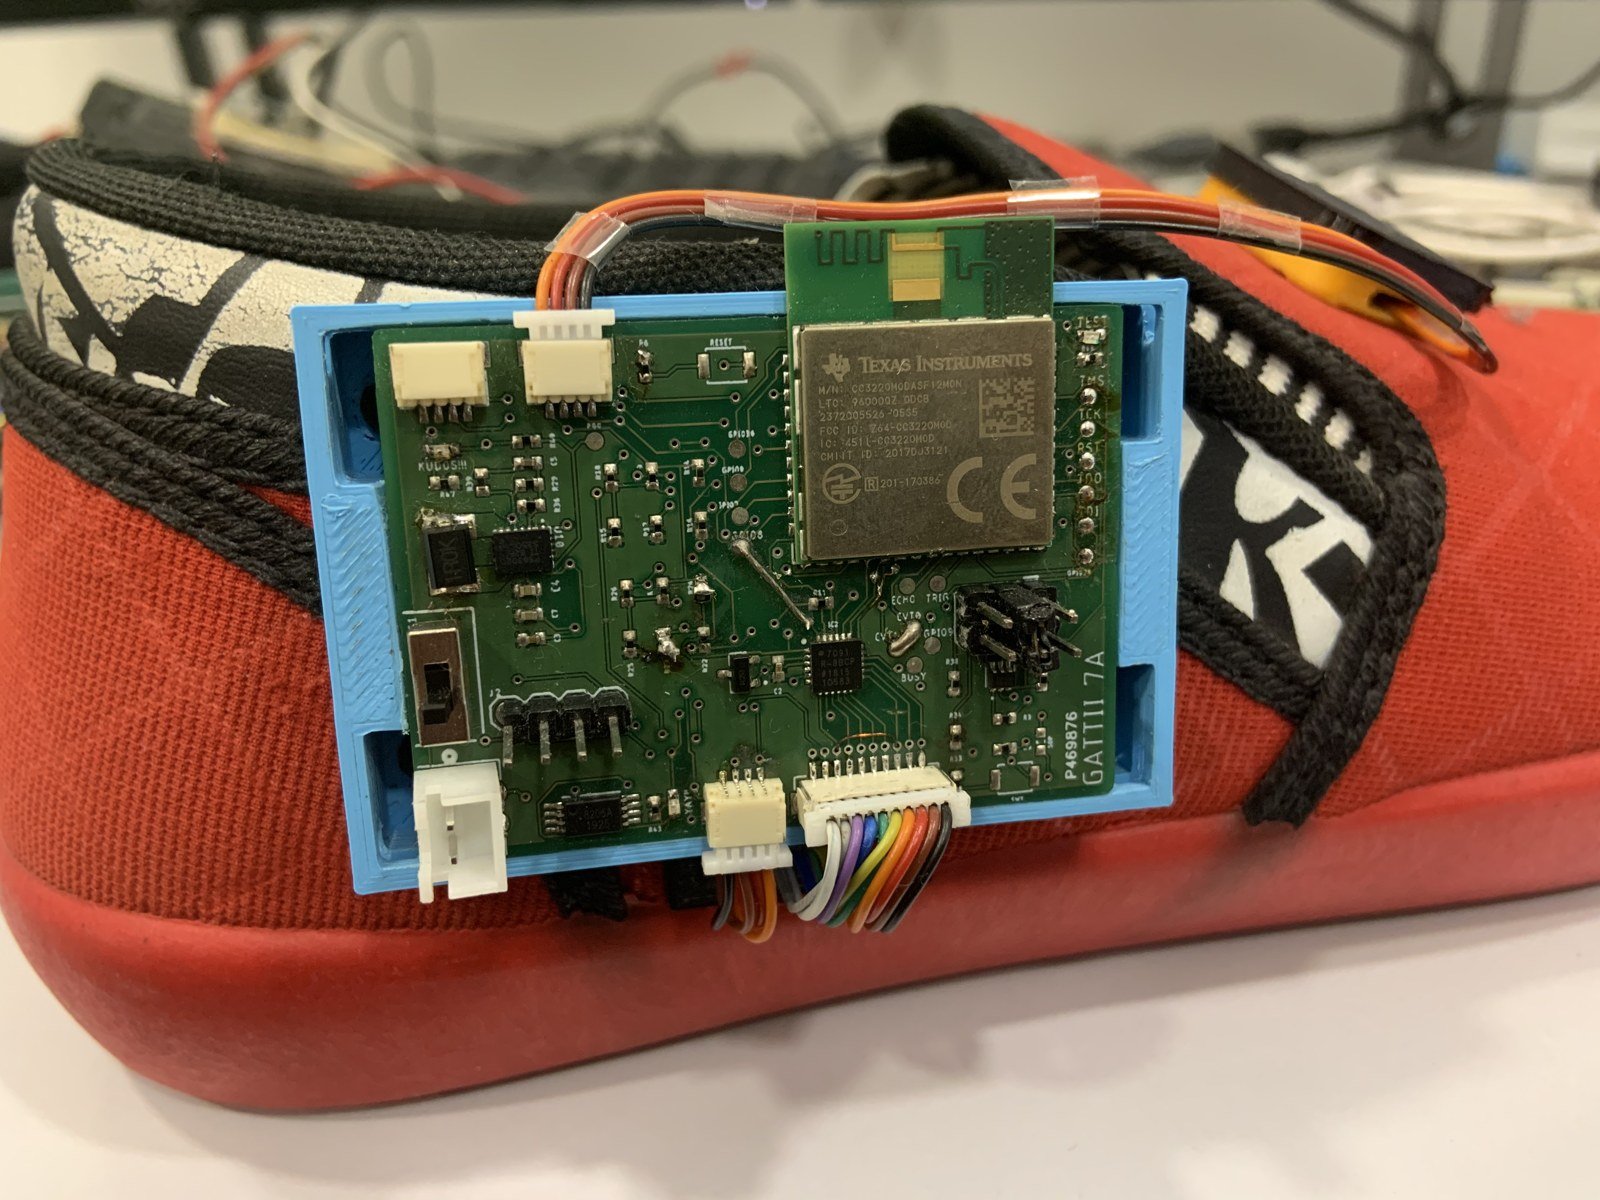
GATTII custom PCB prototype
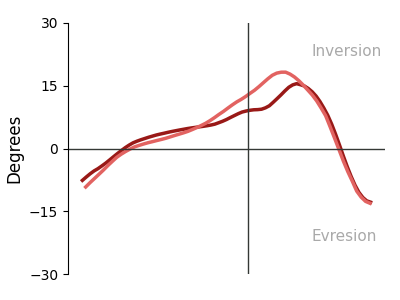
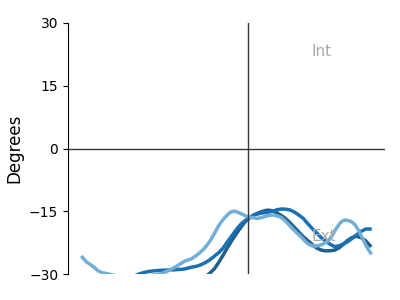
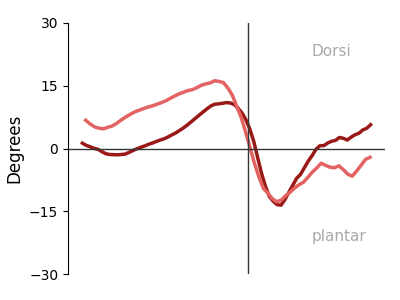
Left foot dorsiflexion heatmap

L Dorsi

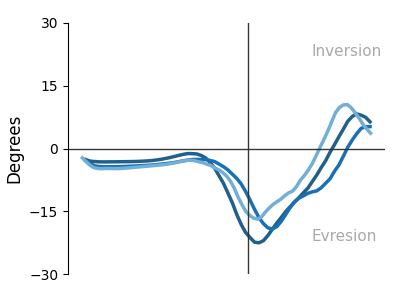
Left foot inversion heatmap

L Inv

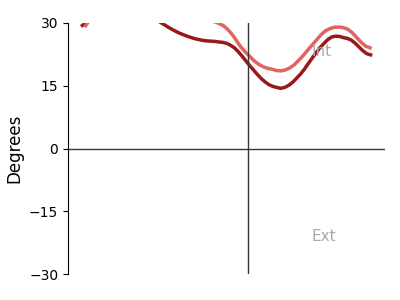
Left foot progression heatmap

L Prog

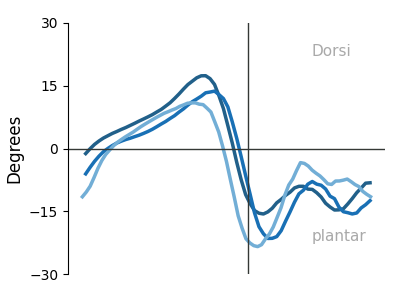
Right foot dorsiflexion heatmap

R Dorsi

Right foot inversion heatmap

R Inv

Right foot progression heatmap

R Prog

Live pressure heatmap output — system-generated clinical report

002

Computer Vision // Haptic Feedback // Deep Learning

RIDGE — Remote Skin Cancer Detection

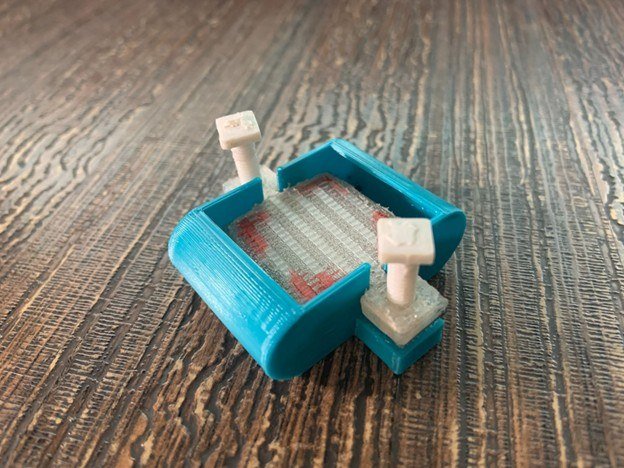
When COVID made in-person dermatology impossible, I built a system combining CNN-based visual classification with a custom non-Newtonian 40×40mm pressure sensor array for 4D tactile-visual lesion profiling. Microsoft Imagine Cup Winner. ISEF 4th Place Grand Award.

Imagine Cup Winner ISEF 4th Place Prov. Patent Haptics
95% CNN Accuracy
10K+ Dataset
4D Lesion Profile
40mm Sensor Array
Read Case Study →
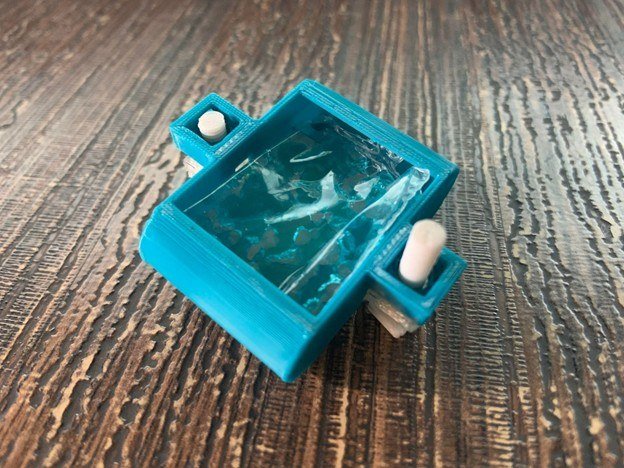
RIDGE sensor array front
RIDGE sensor array back
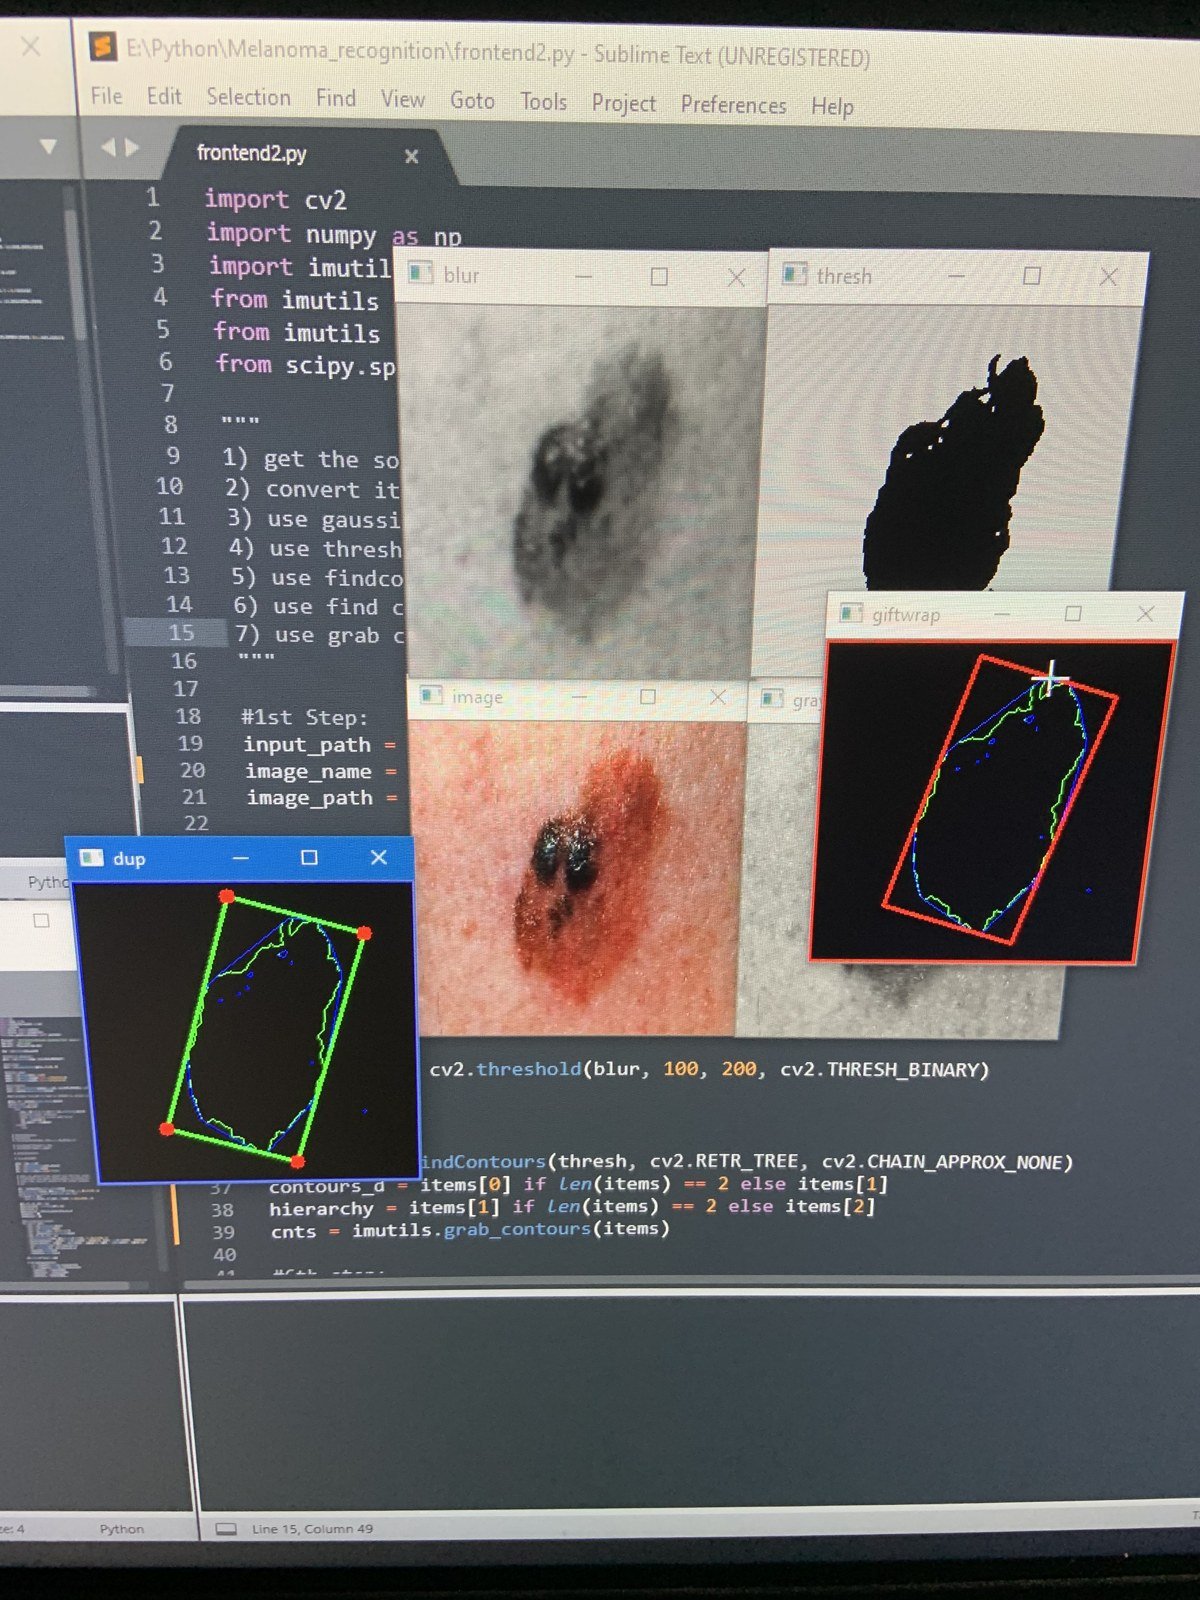
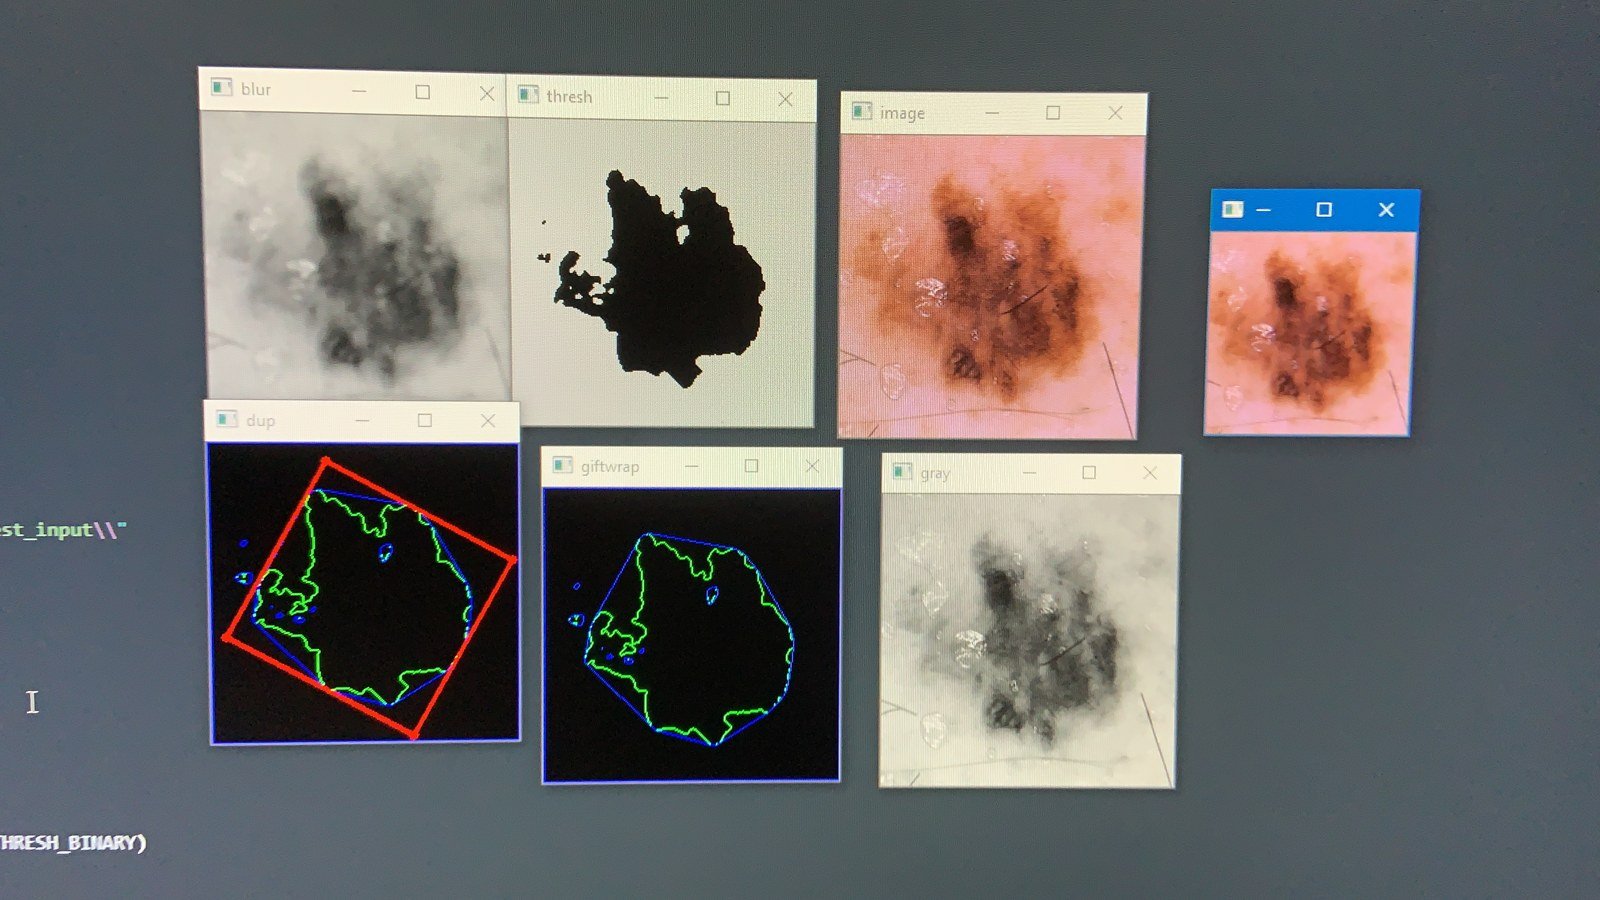
RIDGE CV2 lesion detection code
RIDGE lesion classification dataset

003

Kinematics // Path Planning // Embedded Control

Team GForce — Competition Robots

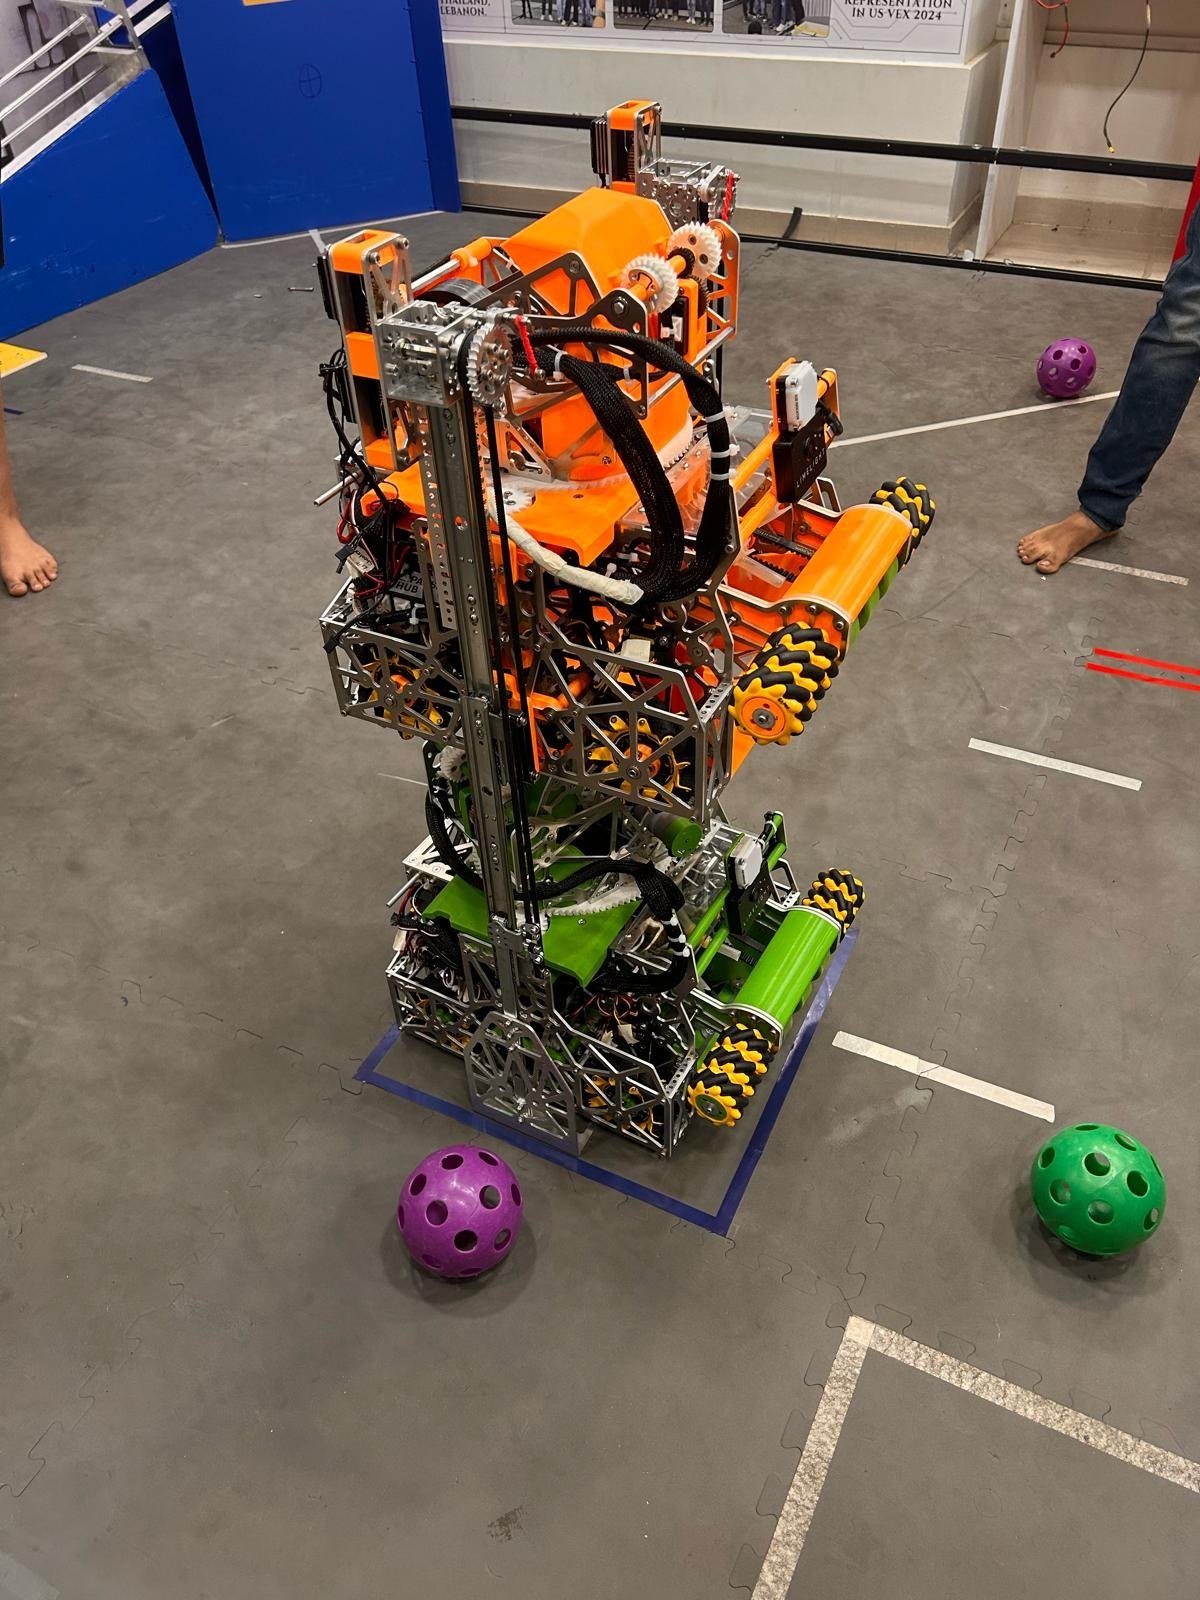
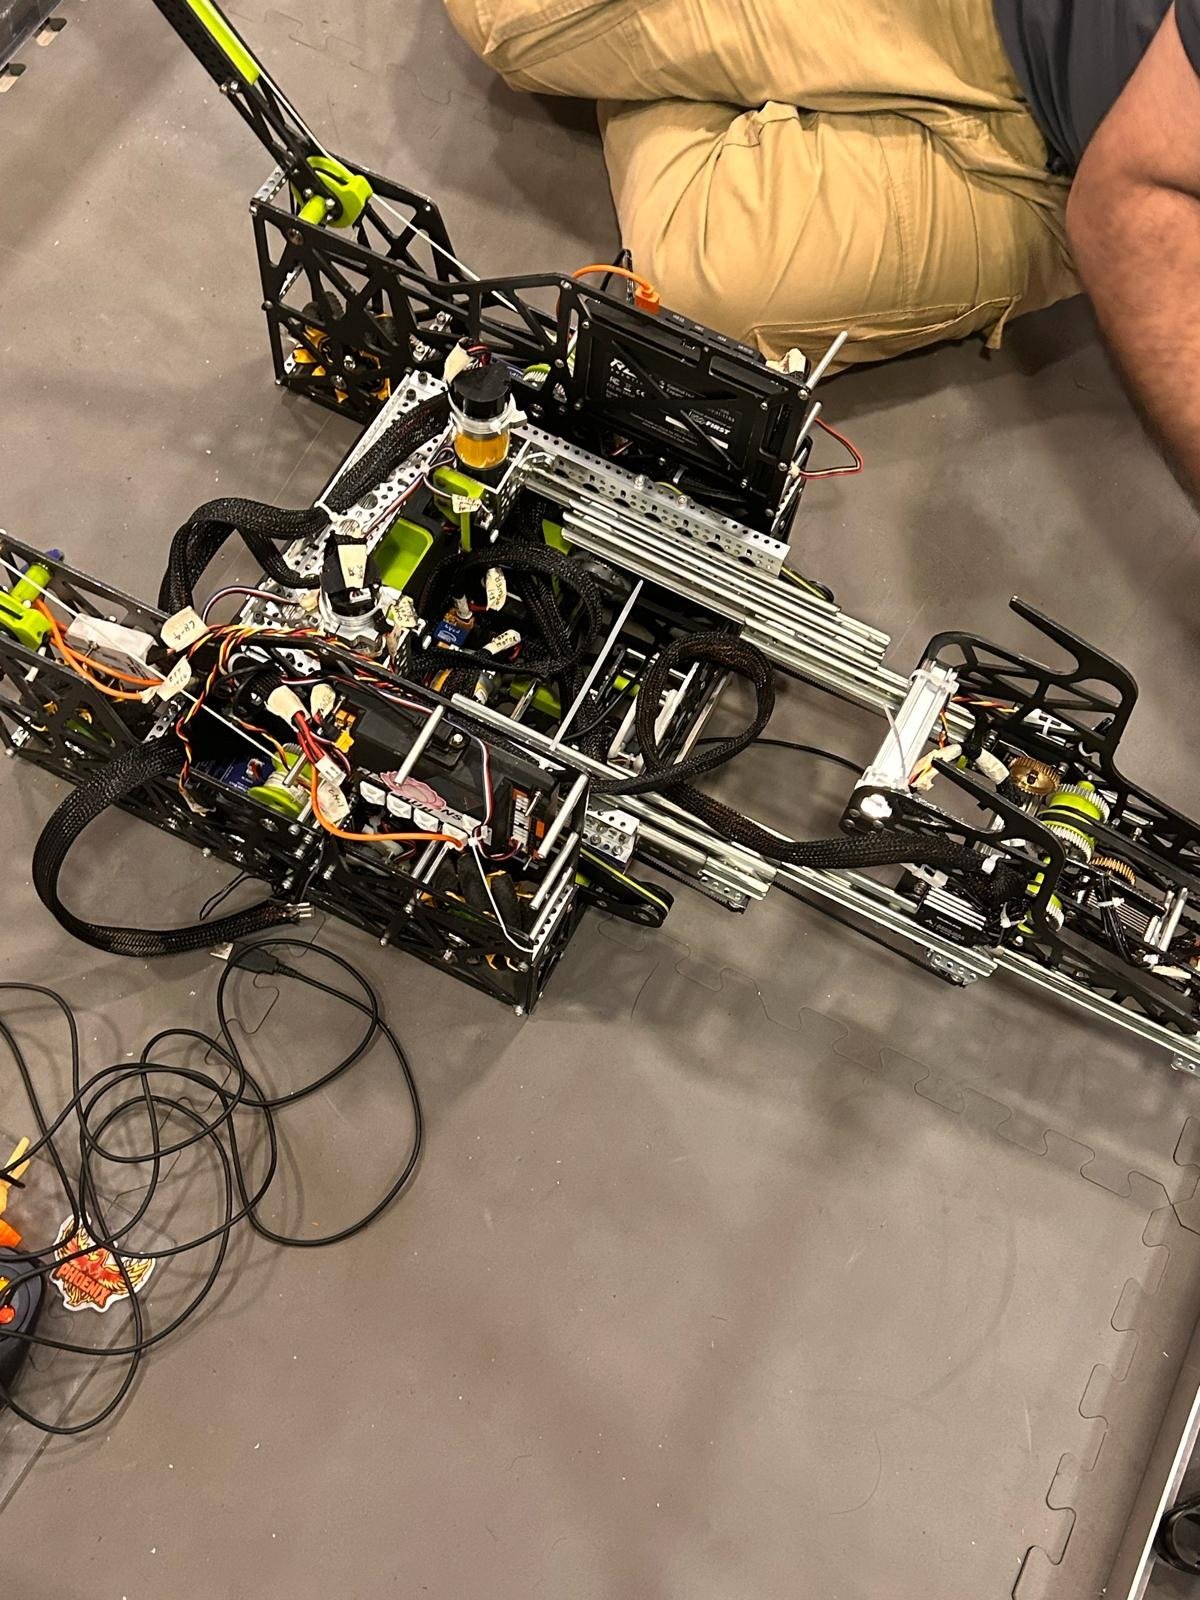
FTC/WRO competition robots with encoder-based Cartesian path planning, Bézier trajectory smoothing, 7-DoF inverse kinematics solving gimbal lock, computer vision field mapping, and physics-based projectile trajectory control. CNC-machined aluminum chassis.

FTC / WRO 7-DoF IK CV Field Mapping Path Planning
7-DoF Articulated
IK Gimbal Lock Solved
CV Field Mapping
WRO Competition
Read Case Study →
FTC robot vertical build with arm extended
FTC robot extended drivetrain top view
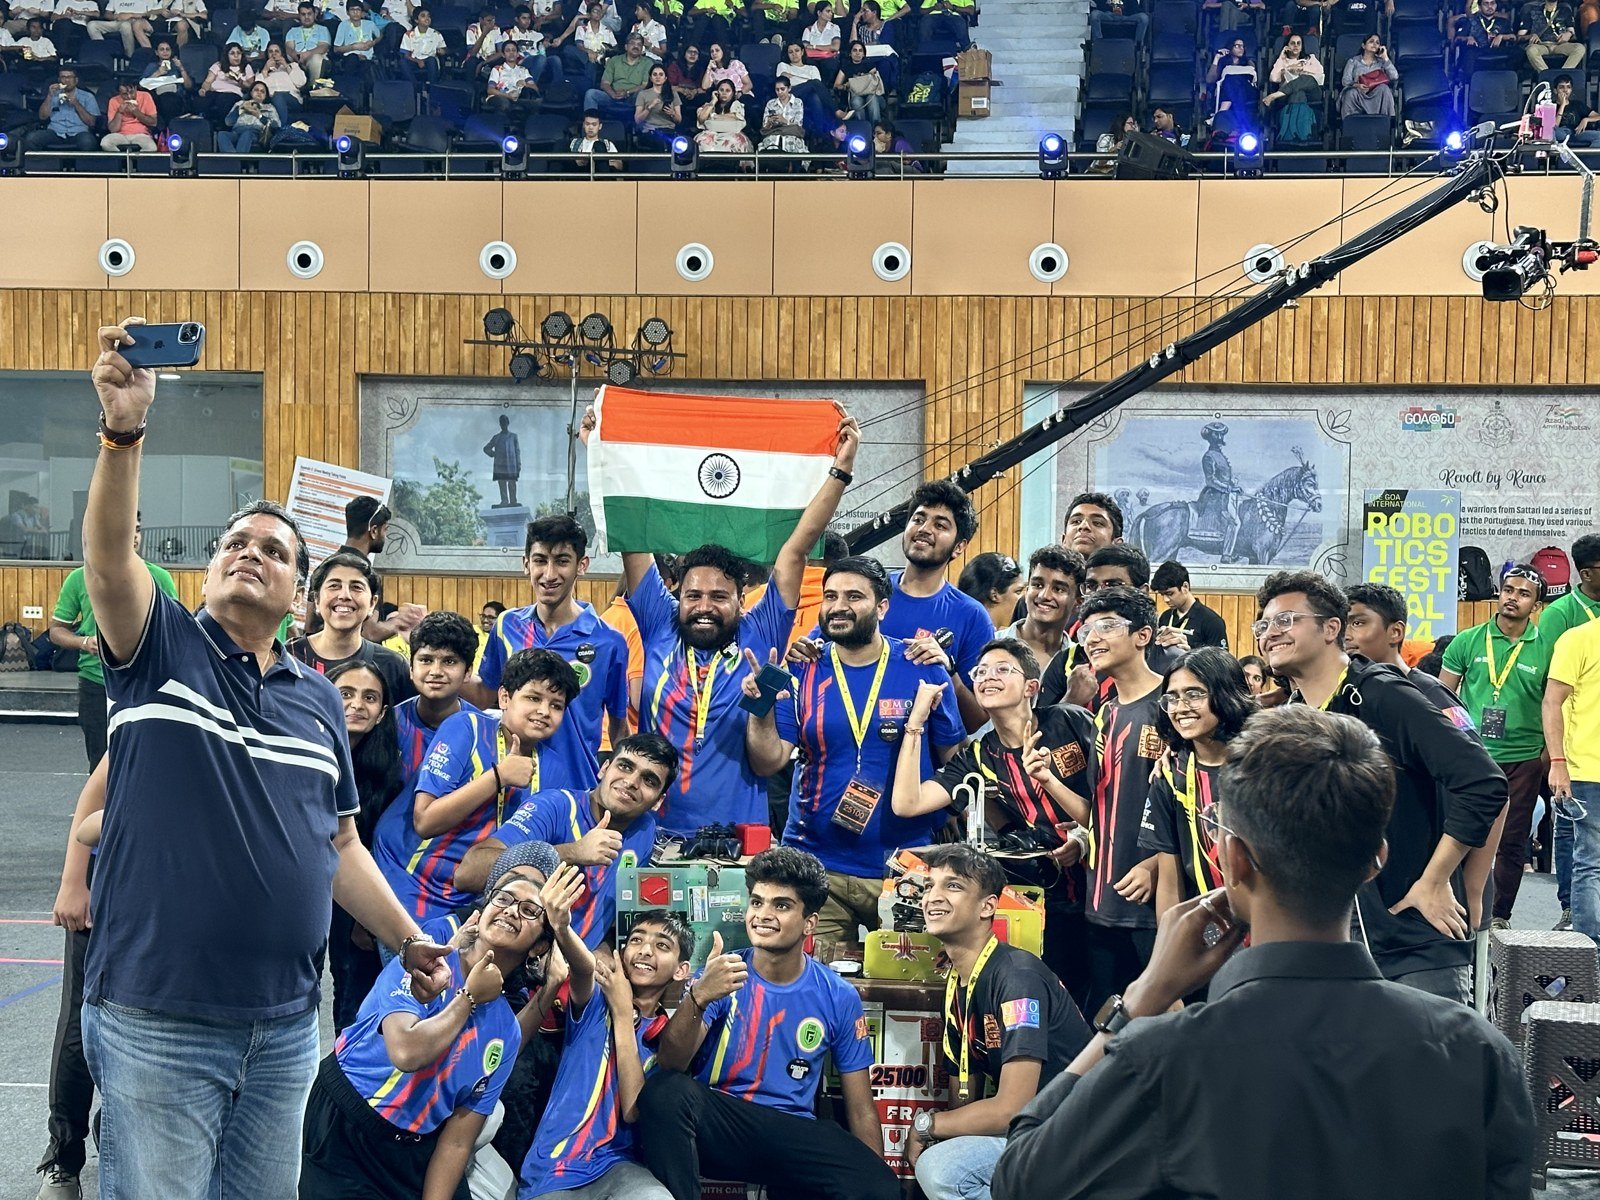
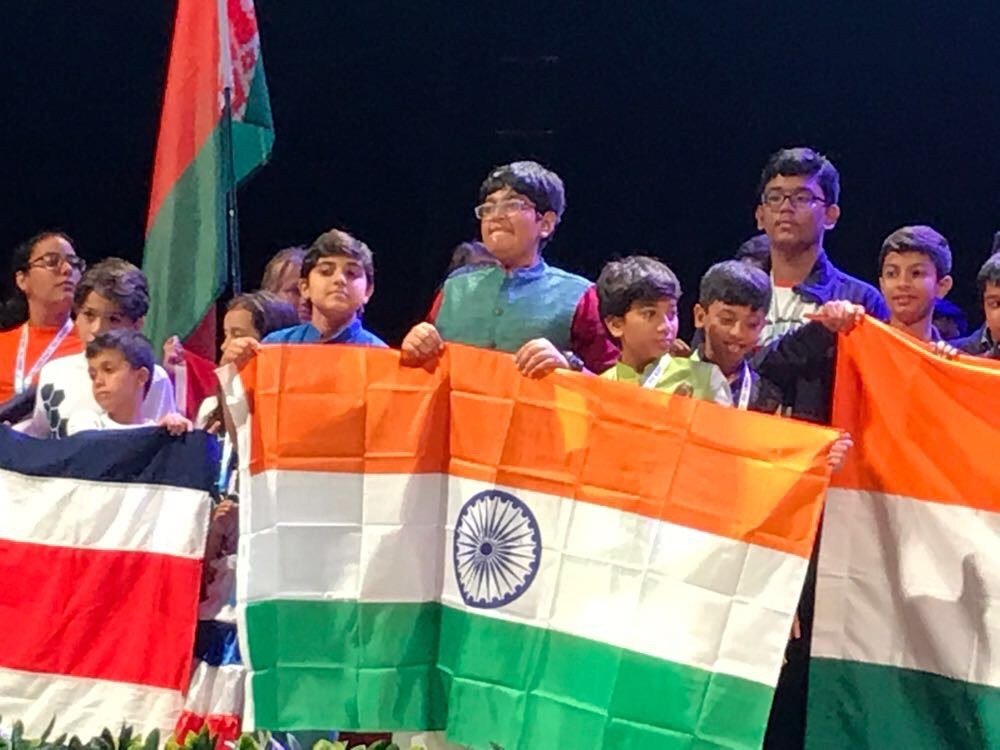
Team GForce at competition with Indian flag
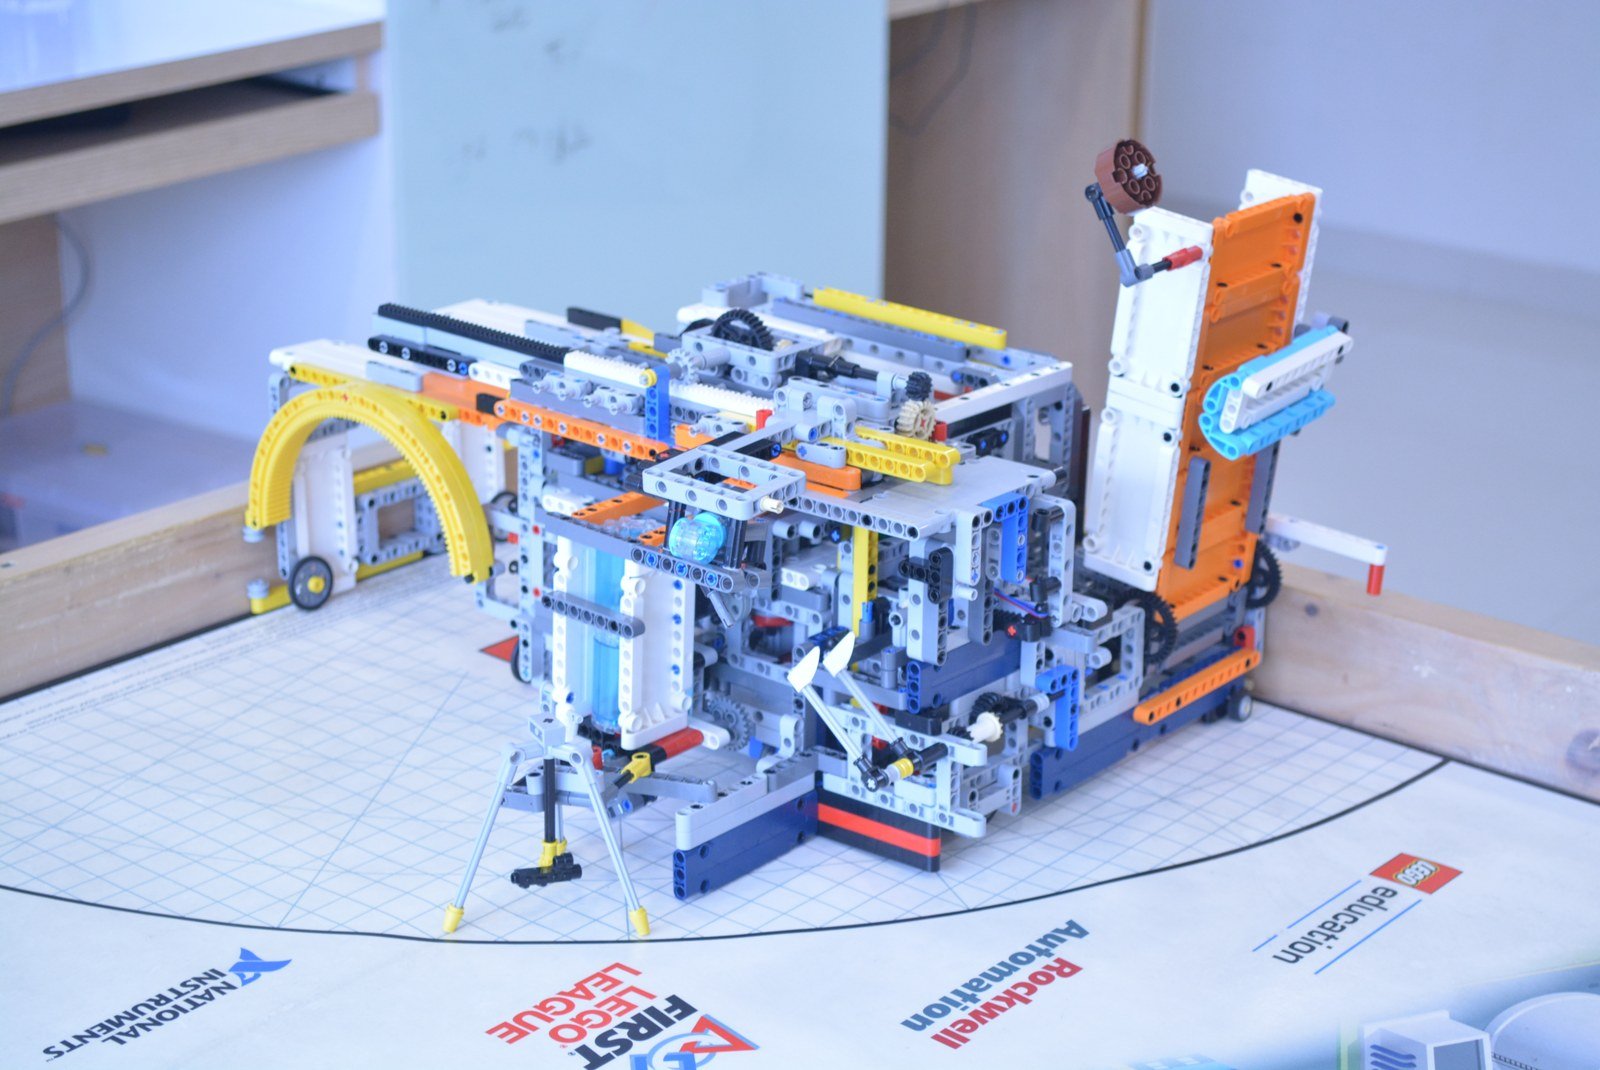
LEGO FLL robot

004

Engineering Leadership // Community Impact

Dharavi Dynamites — Engineering Pipeline

Founded a competitive robotics program in one of the world's largest informal settlements. The hard part wasn't the robots — it was convincing families their children's time was better spent on engineering than wage labor. Six years later: 200+ students, original members now in healthcare and engineering.

6 Years 200+ Students Self-Sustaining
200+ Students
6 Years
13 Core Team
0→1 Pipeline
Read Story →
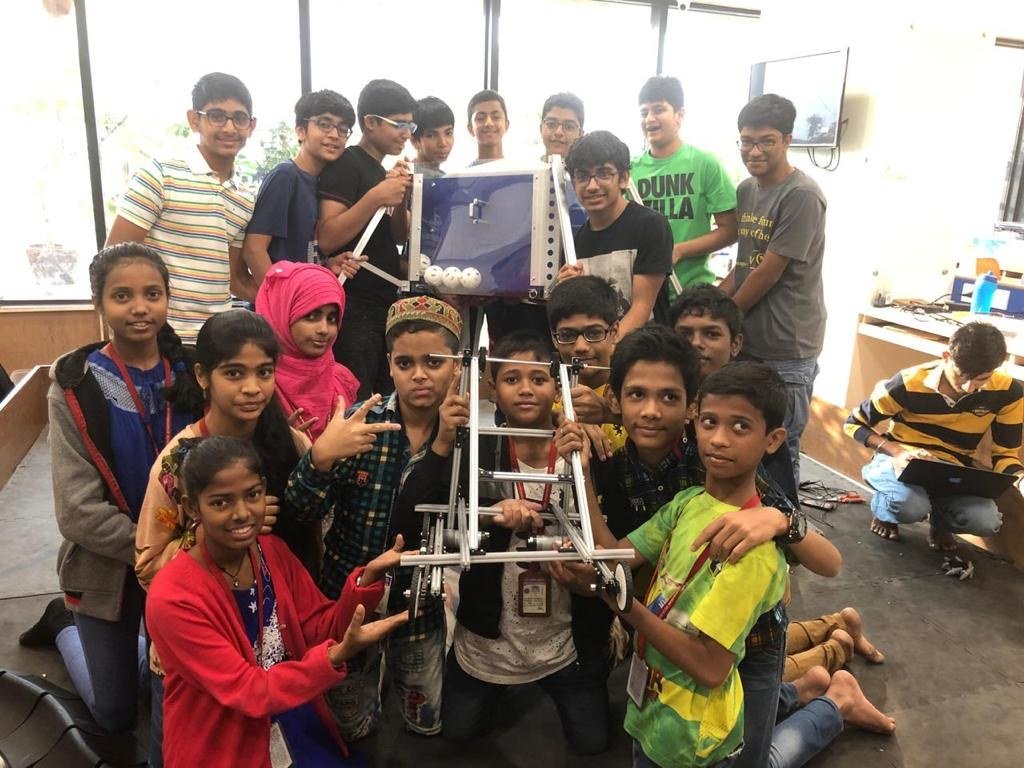
Dharavi Dynamites team with competition robot
Team at international competition 2017
Team GForce at competition
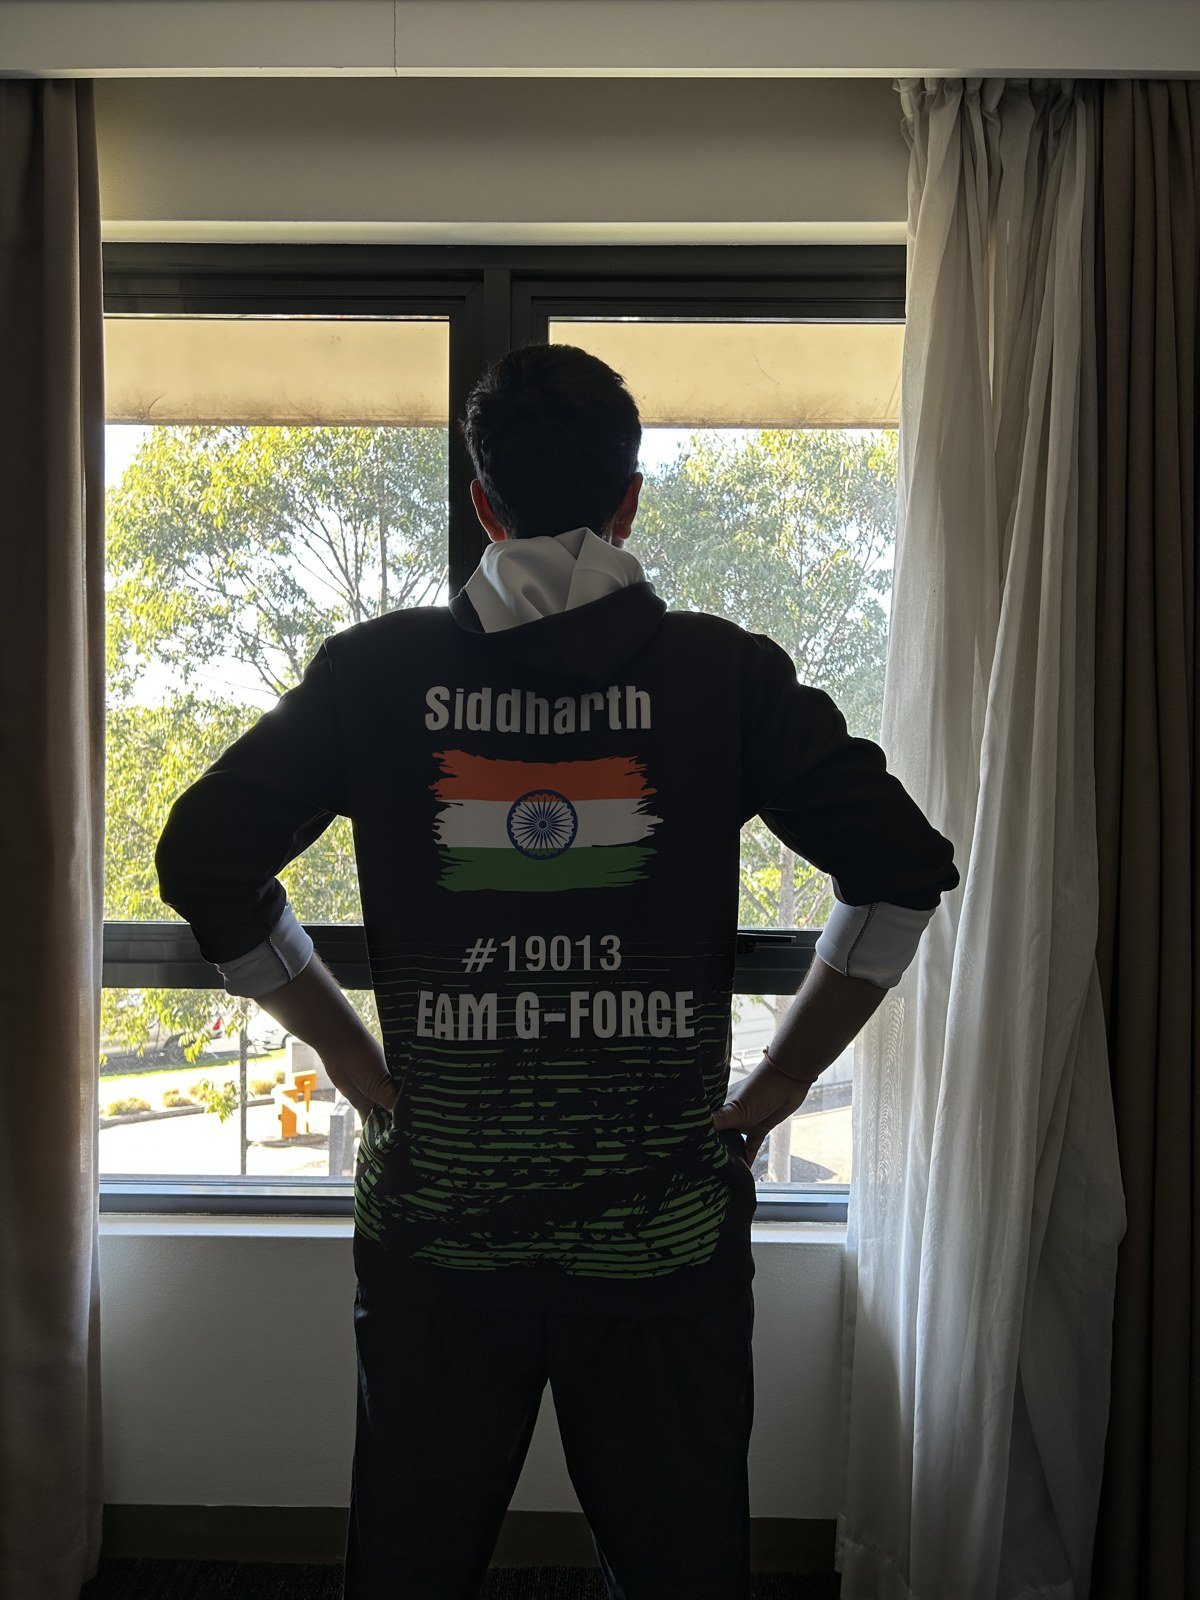
Team GForce competition jersey

// Where I've Worked

Experience

Jun – Aug 2025

Agentic AI Developer Intern

I2E Consulting

FastAPI Groq RAG Pinecone
Multi-agent Jira ticket automation — sub-100ms model response, 500+ tickets/month auto-processed
RAG pipeline with FAISS + Pinecone improved routing precision by 40%
Reduced average ticket resolution time by 30%

Jan – May 2025

Machine Learning Developer Intern

HerHealthAI

Ensemble ML Clinical Data Deployed
98% deployed accuracy on endometriosis screening — ensemble model on 17 clinical biomarkers
KNN imputation + imbalance correction improved dataset reliability by 25%
Model validated and deployed in clinical workflow

Jan – May 2025

Undergraduate ML Researcher

BioSensing Lab, UMass

Time-Series Nanopore Signal Proc.
85% accuracy on nanopore electrophysiology protein identification
Built full segmentation + feature extraction pipeline for neuro-electric event windows
Time-series Random Forest on raw ionic current traces

University of Massachusetts Amherst

BS Computer Science + BS Mathematics (Statistics / Data Science) + Business Minor

Graduating May 2026

// About

The Engineer Behind the Systems

I grew up in a Waldorf school — hands-on learning, understanding before application. Ask why before how. I won't move forward until the understanding feels complete. That's not caution; it's how I avoid building things that fail.

At 9 I was building LEGO robots for national championships. By 16 I was designing PCBs. By 18 I had a patent, angel funding, and a device deployed in physiotherapy clinics across Mumbai. The through-line is always the same: build until it works under real constraints, not just lab conditions.

I'm graduating from UMass Amherst in May 2026 with a dual degree in Computer Science and Mathematics (Statistics/Data Science). I'm looking for full-time roles in medical robotics, embedded systems, or applied ML — anywhere the work has to survive contact with the real world.

"Design within constraints rather than bypassing them. Build systems that complement human expertise, not replace it."

Sidharth Jain

// Let's Build Something

Get in Touch

Seeking full-time roles in robotics, embedded systems, or ML engineering — with a preference for medical technology. Graduating May 2026. Requires H1B sponsorship.

sid@sidjain.co

Location

Amherst, MA — open to relocate

Target Roles

Robotics Engineer · Embedded Systems · ML Engineering · Computer Vision

Ideal Industry

Medical Devices · Wearables · Assistive Tech · Robotics Startups

Availability

May 2026 — full-time

Sponsorship

3 Years OPT - Requires H1B After